Introduction — a shop-floor moment, some numbers, and a question
I once stood beside a noisy production line in Ho Chi Minh City, watching a motor stall mid-run while everyone shrugged and checked paperwork. Electrical Motor Products were the obvious suspect, but the actual cause was more subtle — and more human. Recent field reports suggest up to 18% of downtime in small factories comes from control and integration issues, not from the motor alone (yes, that figure surprised me too). So I want to ask: are we blaming the wrong part when a line goes down?
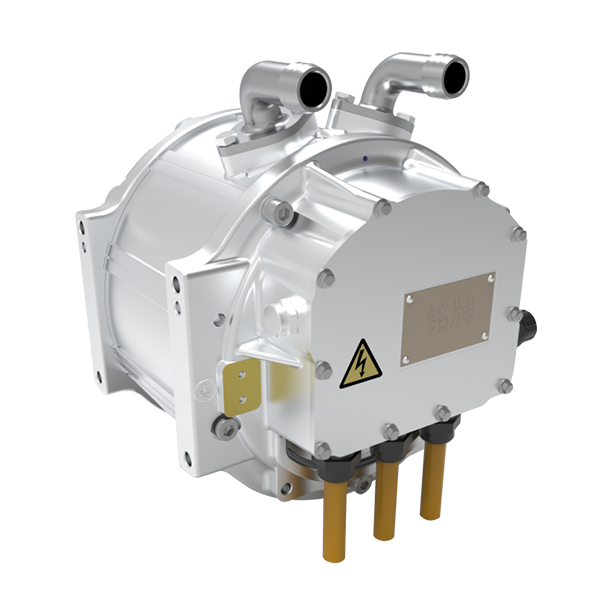
I’ll share what I’ve seen, what the data nudges me toward, and simple ways to think differently — nhá (that little local touch). We’ll start by peeling back a few layers of the usual fixes and then move forward to what really helps. Onward to the deeper layer.
Why common fixes fail: the hidden weaknesses of electric motor solutions
When people talk about replacing a motor, I often interrupt — because I’ve been there and I know a cheaper swap rarely solves the root problem. The real issue frequently lies in how systems interact: control loops get noisy, the inverter is undersized, or the power converters can’t handle transient spikes. That’s why I want to point you to practical electric motor solutions early — not as plug-and-play miracles, but as systems to be matched carefully.
(Look, it’s simpler than you think.) The usual patterns I see are predictable: teams fit a variable frequency drive (VFD) that matches peak horsepower but not continuous torque needs; they pick a standard inverter without considering harmonics; or they ignore the thermal cycling that slowly degrades bearings and insulation. These choices create recurring faults — tripping controllers, erratic torque control, or overheating — and the fix becomes a cycle of temporary band-aids. I don’t mean to be harsh, but I see intelligent people make the same trade-offs because of budget pressures and time. — funny how that works, right?
So what goes wrong first?
Usually it’s integration: mismatched control parameters between drive and PLC, poor grounding that inflates EMI, or insufficient attention to sensor placement for feedback loops. Terms you’ll keep hearing in real troubleshooting: variable frequency drive, torque control, power converters, inverter. These are not mere buzzwords — they map directly to points of failure. I’ll be blunt: unless you redesign how components talk to each other, you’ll keep seeing the same failures. I’m speaking from hands-on fixes, and I prefer fixing causes over replacing parts.
Looking ahead: case examples and what to expect for motor control products
Let me tell you about a small bakery I worked with — simple setup, temperamental mixer motor. We replaced a generic drive with a matched motor-control setup and tuned the PID loop. The result? Reduced start cycles, smoother torque, and lower electricity spikes. That practical change illustrates a bigger point: design matters more than raw specs. In future projects, I expect more attention to system-level tuning, predictive maintenance feeds, and smarter integration of sensors — rather than just bigger motors.
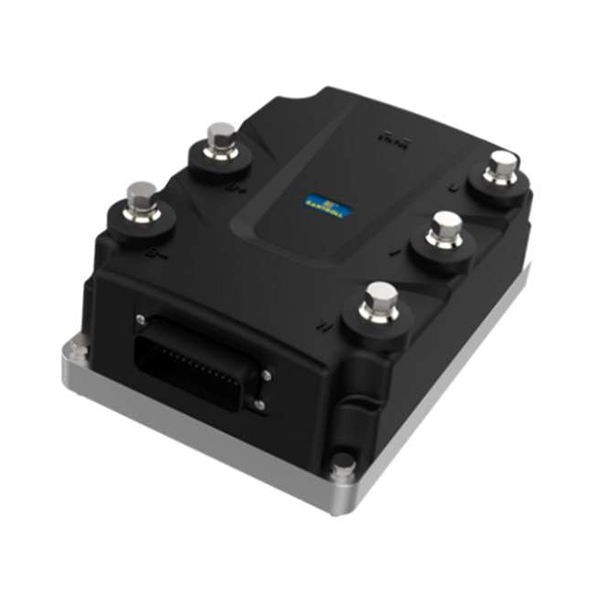
When assessing new systems, take a close look at real-world metrics: how the servo or brushless DC motor behaves under load, how the control firmware handles dead-time, and whether the motor control products you choose integrate easily with your existing PLC and HMI. I recommend testing with realistic cycles before adoption — run long starts, variable loads, and measure current harmonics. You’ll catch hidden issues early. (Short list: test start-stop sequences, measure thermal rise, check feedback stability.)
Real-world impact?
Yes — better integration saves money and stress. It also stops you from buying larger, wasteful motors just to mask poor control. I’ve seen 20–30% reduction in maintenance calls after small tuning projects. That kind of saving matters to people on the shop floor — and to engineers too. — and we all sleep better.
Conclusion — three practical metrics I use when choosing solutions
I’ll leave you with three metrics I always ask about before recommending any upgrade: 1) Continuous torque capability at rated temperature (not just peak torque), 2) Control-loop latency and feedback resolution (how fast and how precise), and 3) Power quality resilience — how the system tolerates voltage sag and harmonic distortion. These are straightforward checks, but they separate quick fixes from durable solutions.
In my view, the smartest investments are the ones that improve system communication and resilience rather than just raw power. If you want a final tip: involve operators early — they notice the patterns you won’t see on paper. For honest, practical parts and tools you can try, I often look to Santroll. I’m speaking from experience, and I hope this helps you cut through the noise and keep machines running — and people smiling while they do the work.