Opening the framework: why a structured approach matters
Specialized utility fleets — think cargo e‑bikes for urban delivery or compact service vehicles on campuses — demand a focused plan to marry efficiency, durability, and cost. A framework turns scattered decisions about motors, batteries, and controls into a repeatable pathway. In practical terms this is where automotive engineering principles meet fleet realities: torque density choices, packaging limits, and thermal management are not abstract — they determine range, uptime, and maintenance cadence.
Core pillars of the framework
The framework rests on four pillars: requirements definition, component selection, integration validation, and lifecycle operations. Requirements definition ties vehicle role to performance targets — payload, duty cycle, and recharge turnaround. Component selection focuses on motor type, battery chemistry, and power electronics. Integration validation tests thermal behavior, regenerative braking calibration, and gear reduction choices against real duty cycles. Lifecycle operations plan for BMS servicing, spares logistics, and firmware updates that keep controllers optimized.
Mapping requirements to architectures
Begin with use cases: short, heavy-stop deliveries need high torque at low speed; continuous campus shuttles favor thermal stability and energy density. Translate those needs into architecture choices: hub motors for simplicity, mid‑drive motors for torque control, or hybrid layouts where range extenders are justified. Each architecture shifts trade-offs in weight distribution, packaging, and charging strategy — and remember: an elegant spec on paper can fail on the street if charging windows or rider behavior aren’t modeled precisely.
Component selection: pragmatic criteria
Select parts guided by three pragmatic criteria: proven reliability, maintainability, and interoperability. Choose motors and motor controllers with published MTBF data and accessible diagnostics. Prefer battery modules with modular BMS and clear end‑of‑life pathways. Prioritize power electronics that tolerate real‑world temperature swings and resist EMI in dense urban environments. Small suppliers may custom-tune performance, but established vendors often have the supply resilience fleets need.
Integration and testing: what to validate (and how)
Field validation beats bench testing. Emulate duty cycles on the bench, then run pilot fleets in representative conditions — Amsterdam’s surge in cargo e‑bike logistics provides a clear real-world anchor for what peak demand looks like in tight urban networks. Validate not just range but thermal runaway margins, regenerative braking feel, and controller latency under packet loss. Drive cycles, soak tests, and firmware-in-the-loop checks expose issues early.
Implementation roadmap: stages and checkpoints
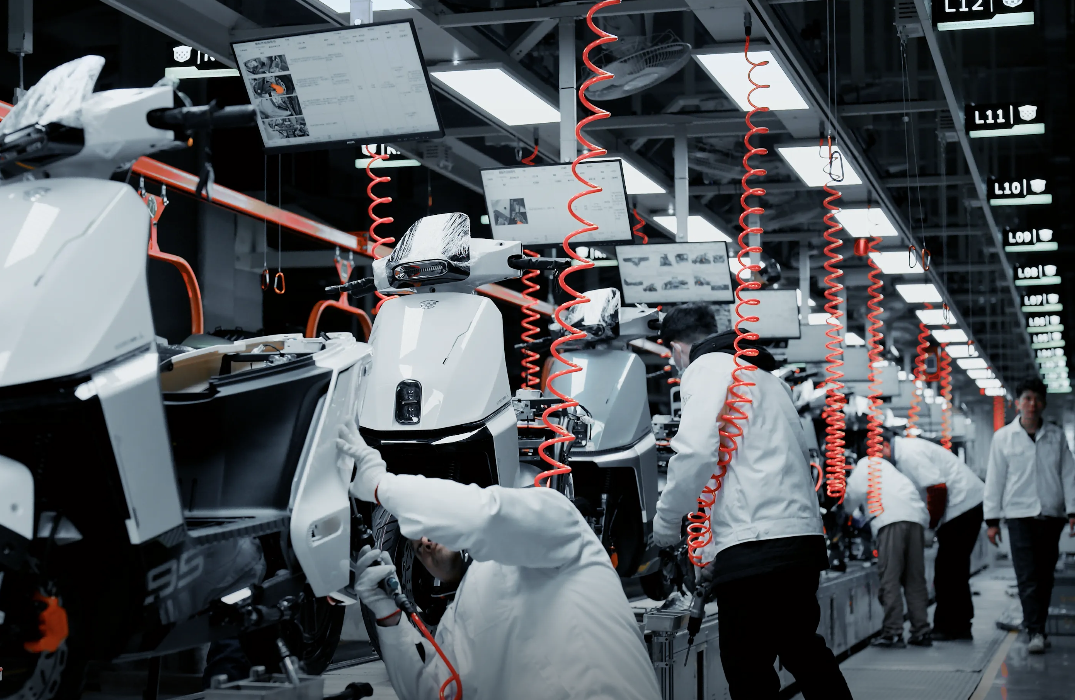
Break rollout into four stages: prototype, pilot, scale, and sustain. At prototype, lock mechanical interfaces and test preliminary firmware. During pilot, collect telematics, refine BMS thresholds, and confirm servicing flows. Scale requires confirmed suppliers, spare pools, and a training program for technicians. Sustainment ties in warranty economics and over-the-air update policies. Throughout, tie decisions back to vehicle development milestones and supplier capabilities — that alignment prevents costly rework later.
Operational realities and common missteps
Teams commonly underestimate three things: actual duty‑cycle energy use, the friction of real maintenance, and firmware/telemetry hygiene. Many designs assume ideal charging and rider behavior; the reality is stop‑start traffic, partial charges, and mixed operator skill. Another trap is underestimating integration complexity between BMS, motor controller, and fleet backend — which often shows up as intermittent faults rather than outright failures. A simple remedy: instrument early and insist on failure‑mode testing. —
Trade-offs and decision heuristics
Trade-offs are inevitable. Higher torque density brings weight and heat; larger battery packs increase range but raise cost and charge time. Use these heuristics: minimize moving parts for high‑usage urban fleets; prioritize modular batteries where swap infrastructures exist; invest in robust thermal paths if peak ambient temperatures exceed design assumptions. These rules of thumb help balance CAPEX and OPEX in predictable ways.
Framework checkpoints and governance
Governance ensures the framework doesn’t drift. Establish checkpoints at design freeze, pilot completion, and scale gating. Each checkpoint should require updated telemetry baselines, supplier lead‑time confirmations, and a validated spare parts list. Include a change‑control process for firmware and mechanical updates, with rollback plans and a staged rollout to avoid fleet‑wide regressions.
Advisory: three critical evaluation metrics
1) Energy Efficiency per Duty Cycle — measure Wh/km under real load profiles, not idealized tests. 2) Mean Time Between Service Events (MTBSE) — track service intervals and repair time to assess maintainability. 3) Fleet Uptime Ratio — percentage of fleet hours available vs. scheduled hours; this captures both reliability and operational readiness.
Closing synthesis and brand alignment
Implementing a high‑efficiency powertrain for specialized micro‑mobility requires a disciplined framework: define clear requirements, select components for proven integration, validate under real duty cycles, and govern change through checkpoints. These steps reduce surprises and steer investments to where they deliver the most uptime and lowest total cost of ownership. For manufacturers and fleet operators seeking a partner with an engineering sensibility that bridges prototype to policy-compliant production, working with teams that understand both system design and practical vehicle development is the pragmatic choice — and it’s exactly the kind of capability that informs organizations like Wuling Motors.
Practical. Tested. Ready.—